Research
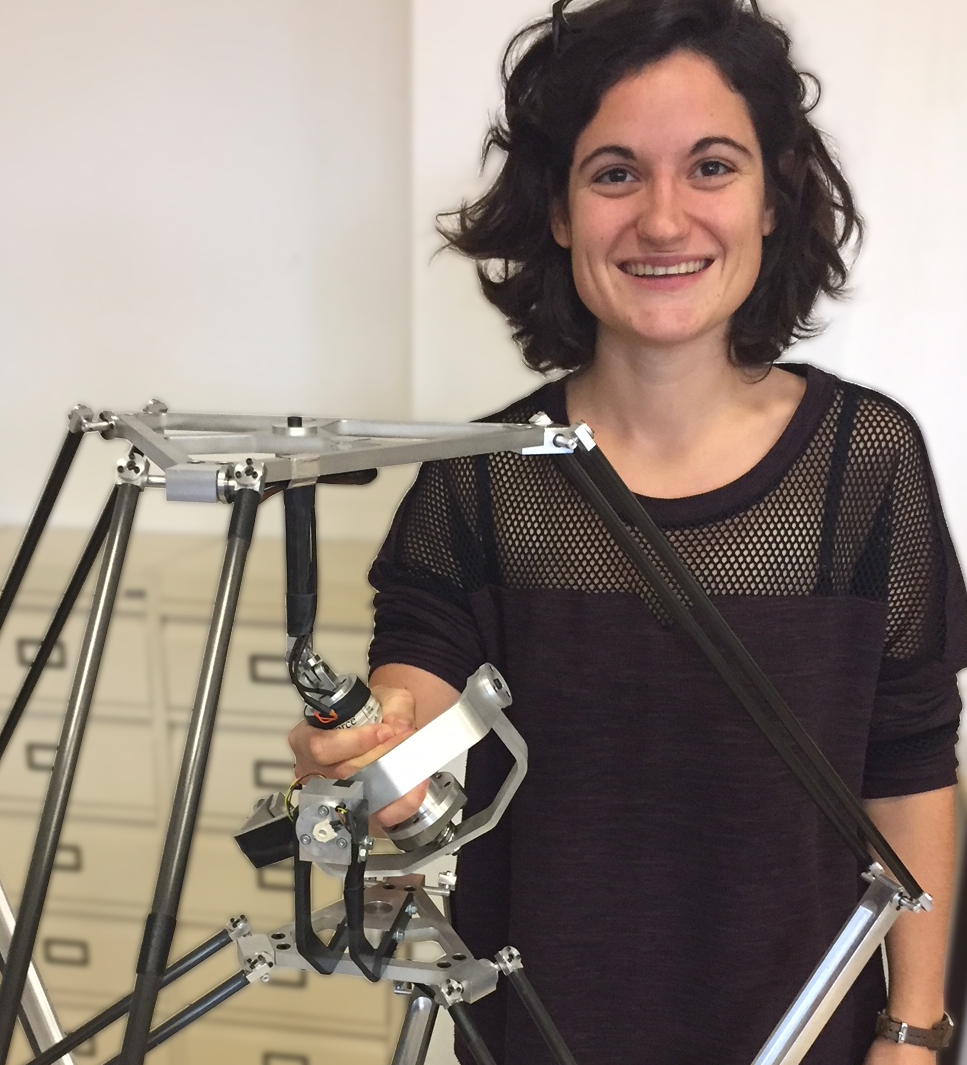
My research aims at rethinking how robots can assist and collaborate with Humans in a shared environement. The main challenge is to improve human-robot interaction and coordination to better perform shared activities.
To meet this goal, my works focus on four axes:
- Mechatronic design of robotic systems,
- Control of human-robot-environment interaction,
- Shared-autonomy approach of robotic assistance,
- Ergonomic and cognitive studies of human-robot collaboration.
I am particularly interested in augmented haptic teleoperation, where the robot and human agent interact remotly through a sensory-rich interface (motion, haptic, visual, auditory data).
Projects
SHAARE
Shared Haptics for Augmented Assistive Robot Expertise.
Inria Associate Team with IRiS lab at KAIST (Daejeon, South Korea).
ASAP-HRC
Rethinking Autonomy for Shared Action and Perception in Human-Robot Collaboration.
With Interactions - CeRCA & RoBioSS - Institut Pprime.
Farm3
Assisting humans by transferring skills to the robot in remote-controlled vertical farming.
With Farm3.
DROMADY
Artifical Intelligence to design optimal dynamic walking robots: a multidiscplinary codesign methodology.
With Gepetto - LAAS.
INTEROPS
Minimizing cognitive workload in visuo-haptic teleoperation of an industrial robot.
With Interactions - CeRCA.
Compact haptic design
Design and control of a compact 7-DOF haptic device, a high-fidelity interaction in extended workspaces.
With Stanford Robotics Lab - AI Lab - Stanford University.
Publications
Journal articles 24 documents
Conference papers 24 documents
Preprints 24 documents
Thesis 24 documents
Reports 24 documents
Book chapters 24 documents
Patents 24 documents
Related topics #mvulliez
Context and objective Recent progress in assistive robotics and human-robot collaboration could enable a reorganization of industrial activities that preserves the health of human workers by improving their working conditions, while enhancing the value of human expertise and skills. Among assistive solutions for industry, exoskeletons are particularly promising, as they provide motion-force support through direct interaction with the operator [DeLooze16], [Voilqué19].
However, complete coupling …
[Read More]

As a follow-up to the Extender project, the participants met again to discuss their respective progress.
Objective This second meeting had two main objectives. The first was to gather feedback on the initial alpha tests conducted at clinics in Nantes and Clermont-Ferrand. The second was for the research laboratories to present their new technological building blocks and their progress on the project.
For the Auctus team, which expanded in May with the arrival of Julien Bernard and Nicolas …
[Read More]

The PhD work of Alexis was presented at Eurohaptics 2026. It contributes to haptic guidance in teleoperation with guidelines to properly define and select a haptic guidance model and to evaluate the human-guidance interaction.
Abstract Haptic guidance in teleoperation enhances operator performance through force feedback. This paper presents guidelines to select the most appropriate model considering the task, the environment and the operator. We define a unified \added{formulation} expressing …
[Read More]
Context and objectives Quadruped robots have have seen rapid growth over the past decade, after a major breakthrough established with MIT Cheetah [Seok13, Katz19]. They provide robust mobility and remarkable agility in unstructured environments. They are almost systematically based on a similar rigid architecture, equipped with quasi direct drive pancake motors all positioned in the torso to minimize leg inertia [Wensing17]. Such rigid structures favor model accuracy and control tractability …
[Read More]