Our paper based on the PhD work of Antun Skuric and Pycapacity on generating online optimal robot motions that best exploit the robot capabilities has been accepted for publication in the IEEE Transactions on Robotics.

Abstract

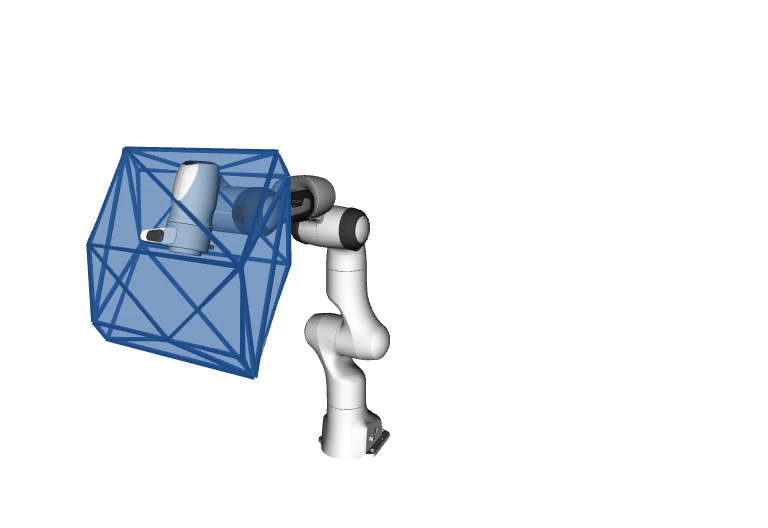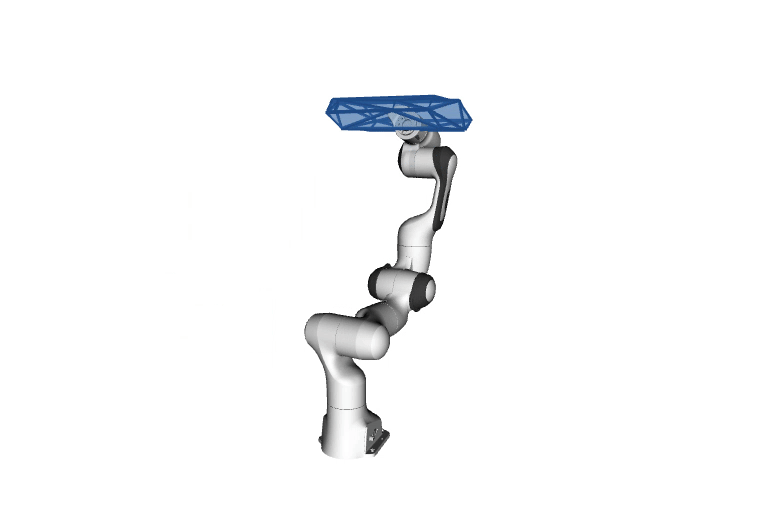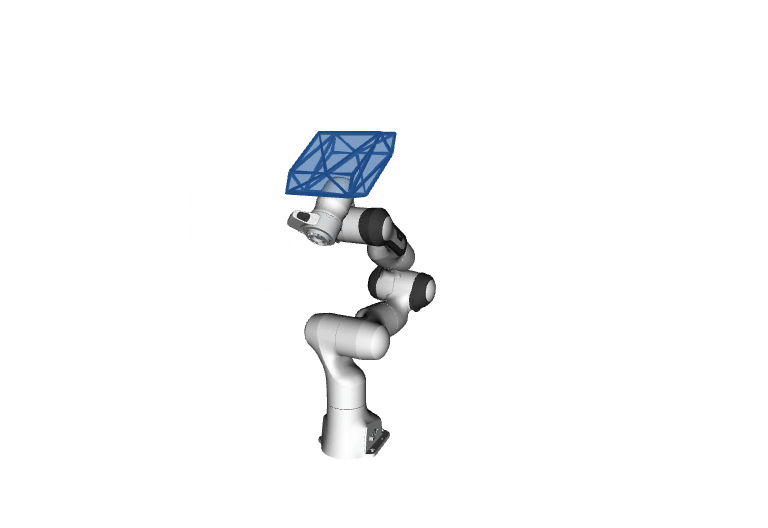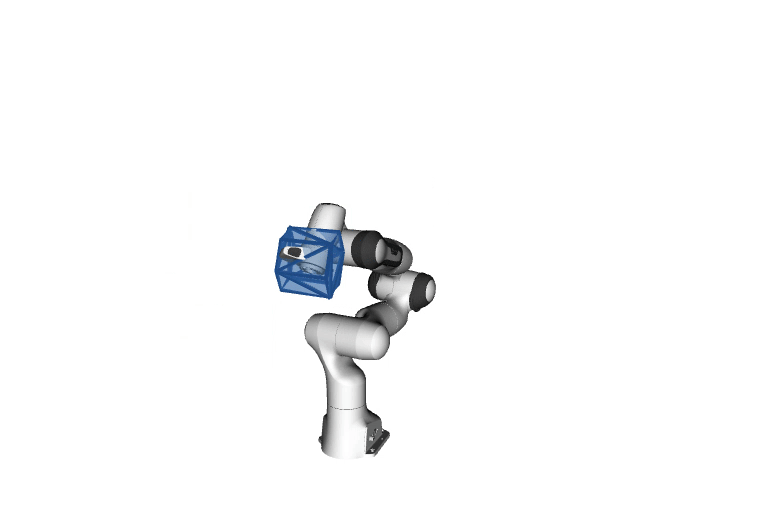
Conforming to safety standards often limits collaborative robots’ performance and size, restricting their applications despite their capabilities. Planning their motions in human environments involves a trade-off between optimal trajectory planning and quick adaptation to dynamic, unstructured spaces. Traditional trajectory planning methods either use simplified robot models and sacrifice robot’s abilities for computational efficiency, or exploit robots’ abilities fully but have high computational complexity and rely on substantial pre-computation. This paper introduces an approach for trajectory planning that exploits robot’s full motion abilities while planning on-the-fly. In each step of the trajectory execution, it evaluates robot’s movement ability using polytope algebra and calculates a time-optimal Trapezoidal Acceleration Profile (TAP) on the remaining trajectory. The method is shown to be near time-optimal (around 5% slower trajectories) by benchmarking it against the state-of-the-art time-optimal method TOPP-RA. The method allows reaching higher velocities (able to plan up to 100% of the robot’s kinematic limits) while at the same time lowering the tracking error (under 4mm) than traditional Cartesian Space planning methods. A mock-up experiment demonstrates its efficiency in collaborative waste sorting using a Franka Emika Panda robot.

[Read More]
Demonstration at Humanoids 2024

Demonstration at Humanoids 2024

Auctus Team Presents Antun’s Work on Polytopes at Humanoids 2024

The Auctus team showcased the work of Antun Skuric on polytopes at the Humanoids 2024 conference. The event, held in Nancy, gathered experts in humanoid robotics and the general public.

Antun’s polytopes (Pycapacity) were used to demonstrate a robot’s capabilities in terms of forces, velocities, and reachable space over a horizon. The proposed demonstration fueled interesting discussions both with robotics scientists and the general public regarding the importance of human and robot capability evaluation for the proper design and control of assistive robots. Leveraging Claire Houziel’s work on the Microsoft Hololens headset, the polytopes were displayed on the robot using Augmented Reality. This demonstration sparked many interesting discussions with the audience and served as an excellent tool for robotics mediation.

[Read More]

Abstract

This thesis is based on vision of the future where robotics and industry are centred around humans, emphasising collaboration between humans and robots rather than mere automation.

In this collaborative future, robots serve as active assistants, coexisting closely with humans and engaging in physical interactions to execute tasks. Such symbiotic systems leverage the unique abilities of both humans and robots, enhancing efficiency and prioritising human safety and well-being through personalised robotic assistance.

[Read More]

Reachable space of robotic manipulators has complex geometry and is often hard to characterise, therefore it is usually calculated in advance by the robot manufacturers and given as an image in their datasheets (as shown on the image on the right). However these images are hard to exploit as they are not analytical solutions to this problem. Even if we would have an analytical solution to this problem it would still not include in its consideration robot’s dynamics, its payload or its actuator torque limits.

[Read More]

Iterative convex hull is a polytope evaluation algorithm developed for the generic class of the linear algebra problems: $$ A\bm{x} = B\bm{y},\qquad \bm{y} \in [\bm{y} _{min}, \bm{y} _{max}] $$

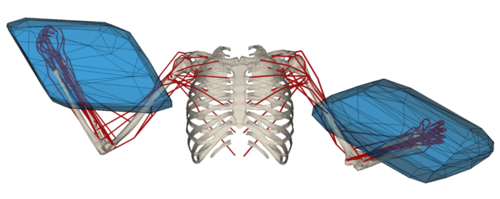
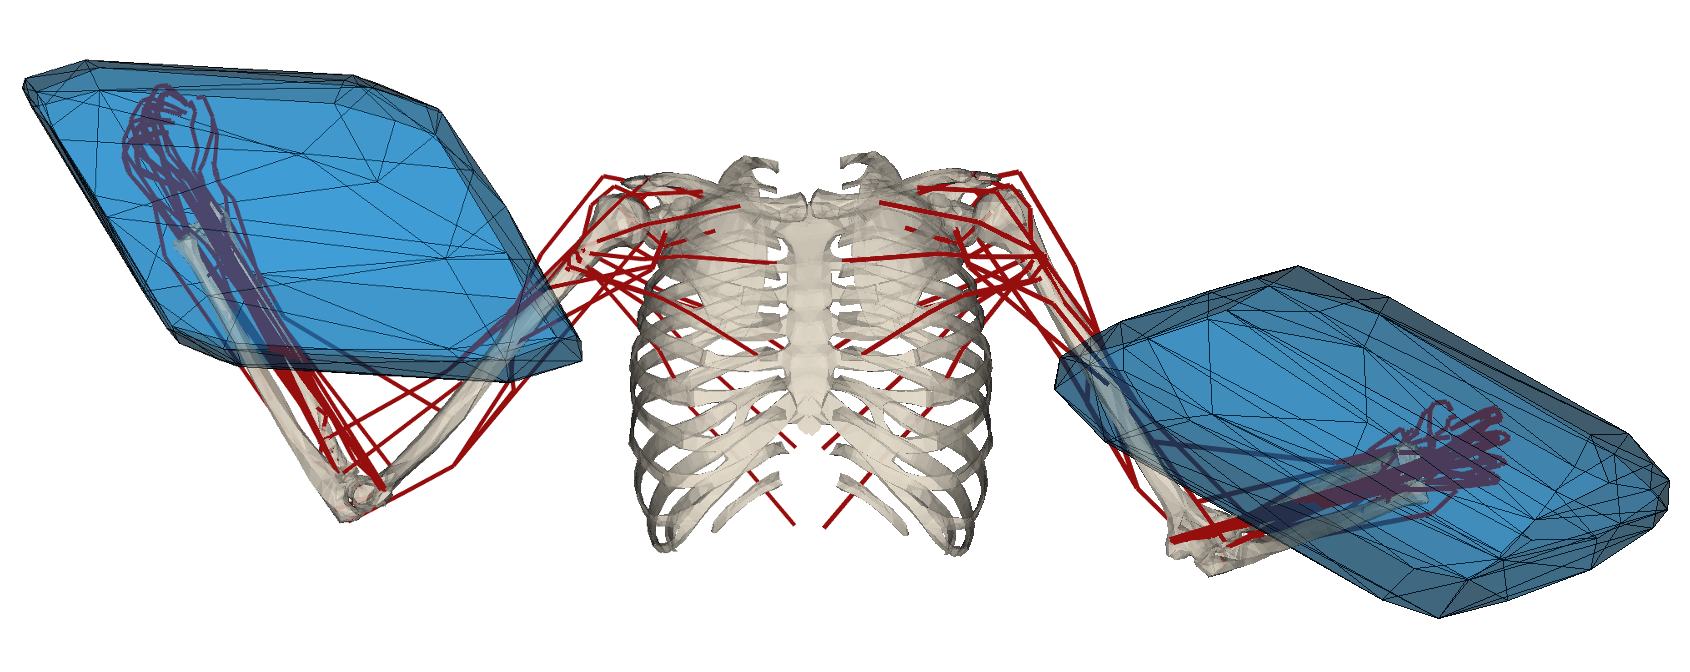
This type of problems can be found in many different domains, one of them being the wrench capacity analysis of the human musculoskeletal models. In this paper the method overview is given as well as the verified on the assistive robotics scenario.

[Read More]

The Auctus team focuses on developing the robot control and analysis techniques suitable for human-robot physical interaction, taking in consideration the true limitations/capabilities of the robot and its human counterpart. In order to gather real-time knowledge about the human’s capabilities it is necessary to measure its posture (joint angles, positions,…) in real-time as well. More specifically, in many cases we are only interested in acquiring posture of a specific part of the human body, for example the upper body, or one arm.

[Read More]
Airbus

Airbus

Airbus is a European multinational aerospace corporation. Airbus designs, manufactures and sells civil and military aerospace products worldwide and manufactures aircraft in Europe and various countries outside Europe.

The collaboration aims to design a constellation of mini-satellites and one of the challenges is to rethink their production, in particular through robotic assistance of operators. In this project, we have developed a coupled model of human-robot physical capabilities.

[Read More]
../resources/lichie.png

The LiChIE project (funded by BPI) aims to design a constellation of mini-satellites for optical Earth observation. Among many other topics, this requires to rethink the way sattelites are being produced in order to ease this highly complex process. There is actually an unprecedented economical and societal demand for robots that can be used both as advanced and easily programmable tools for automatizing complex industrial operations in contexts where human expertise is a key factor to success and as assistive devices for alleviating the physical and cognitive stress induced by such industrial task. Unfortunately, the discrepancy between the expectations related to idealized versions of such systems and the actual abilities of existing so-called collaborative robots is large. Beyond the limitations of existing systems, especially from a safety point of view, there are very few methodological tools that can actually be used to quantify physical and cognitive stress. There is also a lack of formal approaches that can be used to quantify the contribution of collaborative robots to the realization of industrial tasks by expert operators. Of course, in the state-of-the-art, existing works in that domain do consider some aspects of the current state of the operator in order to propose an appropriate robot behaviour. One of their conceptual limitations is to consider an a priori defined human-robot collaboration scenario where the expertise of the human operator is of importance but limited to a single operation. The consideration of larger varieties of tasks is rarely considered and, when it is, only a strict separation of the tasks to be achieved by each member of the human-robot dyad is considered. In this project, we propose to develop a coupled model of human-robot physical abilities that does not make any a priori with respect to the type of assistance. This requires to develop a parameterisable generic model of the potential physical link and implied constraints between the human operator and the robot. This model should allow to describe the task to be achieved by the human alone or using a collaborative robot through different interaction modalities. Online simulation of these scenarios coupled with ergonomic and performance indicators should both allow for the discrete choice of the right assistance mode given the task currently being achieved as well as for the continuous modulation of the robot behaviour.

[Read More]