Extract and translate from the ISIR press communicate

Presentation

The EXTENDER project, winner of the Défi Transfert Robotique 2023 call for projects, is developing innovative interfaces to enable disabled people to control a robotic arm installed on their wheelchair. The project is supported by major players such as ISIR (Sorbonne Université / CNRS), LAAS-CNRS, CETCOPRA (Université Paris 1 Panthéon-Sorbonne), the Auctus project-team (Inria Centre at the University of Bordeaux), Institut Pascal (UCA / CNRS, secondary supervisor of CHU Clermont-Ferrand and member of Clermont Auvergne INP), start-up ORTHOPUS, and a health center: ESEAN AFP France handicap. EXTENDER is part of the France 2030 program run by the Agence Nationale de la Recherche and BPI France.

[Read More]
The SHAARE associate team is created in 2024 between the IRiS lab at KAIST and the Auctus team at Inria, to share our complementary methodological orientations in haptic shared control. Together, we aim at developing shared-control approaches that, either, better guide the human through adaptive haptic guidance, or adjust the robot behavior according to the human gestures.

The IRiS lab develops virtual-fixture feedback, generated from a task description given by the user. Our partner also studies machine learning strategies to transfer skills from the human to the robot in haptic teleoperation.

[Read More]

This collaborative project started in 2021 between the AUCTUS team at Inria, the RoBioSS team at the Pprime Institute (CNRS), and the Interaction team at the CeRCA laboratory (CNRS). It is co-funded by the ASAP-HRC young-researcher ANR grant and the Perception-HRI Nouvelle-Aquitaine Regional Aid. It aims at rethinking Autonomy for Shared Action and Perception in Human-Robot Collaboration, through transverse studies in robotics and cognitive sciences.

Three scientific axes are studied to develop a human-centered and generic shared-autonomy framework:

[Read More]
MOVER

MOVER

../resources/handle.jpeg

The MOVER project is related to the study of morphological and motor variability of a human operator. Its goal is to develop tools for representing different operators with varying morphologies, mouvement amplitudes and motor variability for ergonomics purposes.

Motor variability : an appropriate level of motor variability can contribute to lower the incidence of musculoskeletal disorder of a human operator. In this framework, the aim of the project is to get a better insight into the motor variability of a human operator through different experimental protocols. In particular, we aim to study the impact of different experimental factors related not only to the task, such as precision, force and time constraints but also to the operator sensory-motor and cognitive status such as fatigue or expertise.

[Read More]

The Portage project aims at developing robotic solutions to support moving heavy structures within industrial environments. Typically, the targeted task is supporting moving an aircraft wing throughout the successive workstations in the industrial facilities. A robotic collaborative plateform is designed, developed and evaluated to increase both productivity and safety for industrial operators.

The contribution from Auctus regards the overall approach for designing the robotic plateform, developing human-robot interfaces, and experimentaly evaluate its impact. Charles Fage, Jean-Marc Salotti and David Daney are involved in Portage. We adopt a task-centered approach consisting of systematically analysing the targeted task (cognitive walkthrough, usage scenarii) as well as the future – robotized – task. This systematic analysis lead to identifying different movement modes of the robotic plateform, as well as supporting decision making through the different design steps across partners.

[Read More]

Completed projects

The SHAARE associate team is created in 2024 between the IRiS lab at KAIST and the Auctus team at Inria, to share our complementary methodological orientations in haptic shared control. Together, we aim at developing shared-control approaches that, either, better guide the human through adaptive haptic guidance, or adjust the robot behavior according to the human gestures.

The IRiS lab develops virtual-fixture feedback, generated from a task description given by the user. Our partner also studies machine learning strategies to transfer skills from the human to the robot in haptic teleoperation.

[Read More]

This collaborative project started in 2021 between the AUCTUS team at Inria, the RoBioSS team at the Pprime Institute (CNRS), and the Interaction team at the CeRCA laboratory (CNRS). It is co-funded by the ASAP-HRC young-researcher ANR grant and the Perception-HRI Nouvelle-Aquitaine Regional Aid. It aims at rethinking Autonomy for Shared Action and Perception in Human-Robot Collaboration, through transverse studies in robotics and cognitive sciences.

Three scientific axes are studied to develop a human-centered and generic shared-autonomy framework:

[Read More]
PacBot

PacBot

../resources/pacbot.jpg

The PacBot project aims to design a semi-autonomous cobotic system for assistance, capable of selecting, synchronising and coordinating tasks distributed between the human and the robot by adapting to different types of variability in professional gestures, while anticipating dangerous situations.

The orchestration of tasks between the human and the robot is difficult because it must answer the question of the distribution of roles within the couple according to the physical and decision-making abilities and constraints as well as the consequences of their interactions.

[Read More]

This ADT (Aide au Développement Technologique) aims to give a technical support for experimental developpement of all Auctus research activities. These technological developments are essentially software developments in the context of capturing human movement and about real-time control of collaborative robots.

The objectives of the ADT come under development, deployment, documentation and support of a software architecture for experimentation in collaborative robotics allowing the short, medium and long term development of the scientific work of Auctus and facilitating their dissemination.

[Read More]
Jessica Colombel, PhD student, works here on human motion capture.

Jessica Colombel, PhD student, works here on human motion capture.

Assistance or collaborative robots aim to preserve the health and well-being of people, in particular by promoting interactions during phases of fragility. There are many ways to interact with robots, but this project only focus on human motion. The goal of the BioMotion project is to find the modalities of representation of movement allowing to extract physical and cognitive information.

[Read More]
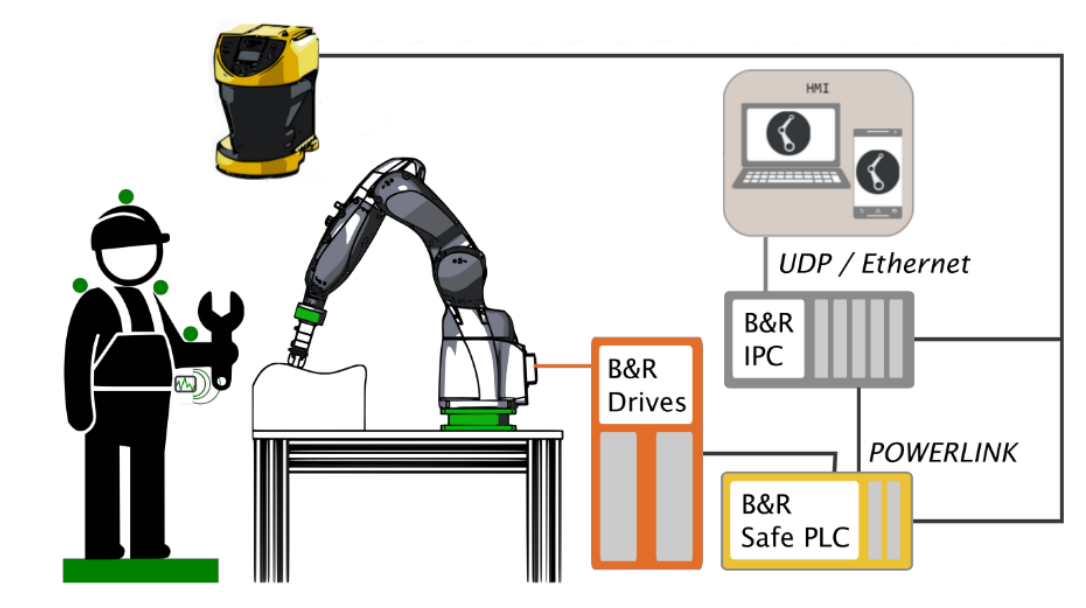
Harry2 project overview

Harry2 project overview

The objective of the HARRY2 project is to attain more advanced workspace sharing capabilities through fully exploiting the collaborative possibilities defined by ISO TS 15066. This is achieved by:

  • Developing PLC software and motion controllers using robot-agnostic industrially-rated components to ease and standardize the development of safe robotic applications with workspace sharing.
  • Integrating state-of-the-art energy-based control algorithms using these industrial hardware components, so that safety is no longer treated as an exception but considered as a constraint when computing the control solution in real-time.
  • Enabling the use of high-level and intuitive teaching interfaces reducing robot programming time and difficulty.
  • Developing a systematic and practical methodology for quantitative safety evaluation.

People involved:

[Read More]
../resources/glovebox/glovebox.png

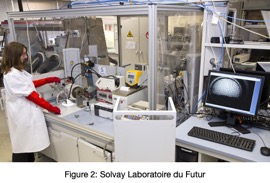
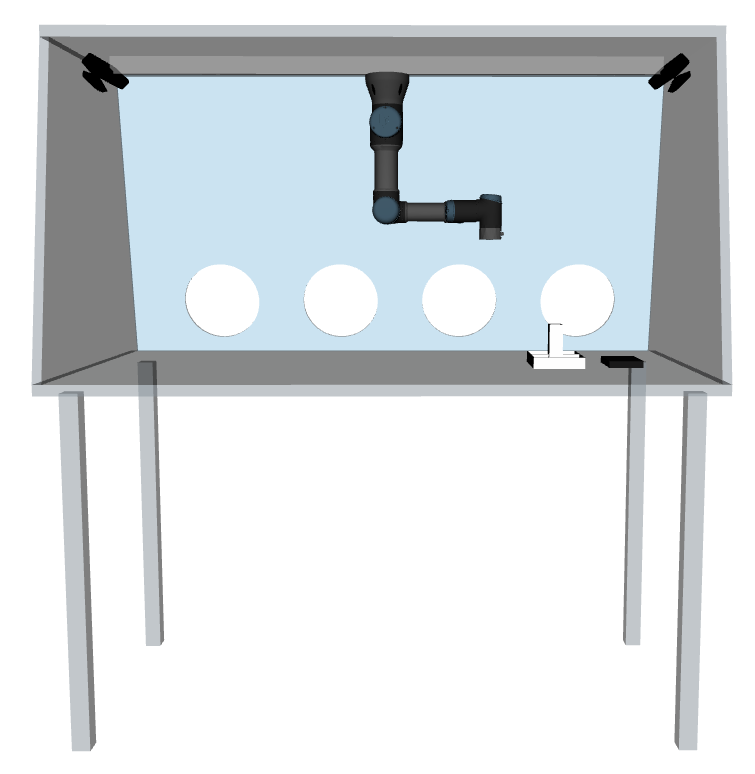
Technicians at LOF handle chemicals elements that needs to be contained in specific environment. To that extent they use glove boxes. The space inside these boxes is constrained and manipulation of objects is not always practicle. To that extent, they want to introduce robots inside the glove boxes to assist the lab technician. A postdoctoral student, Lucas Joseph, has been recruited to build a demonstrator of such technology.

Specifications

In this project the robot has to realise three tasks :

[Read More]
../resources/lichie.png

The LiChIE project (funded by BPI) aims to design a constellation of mini-satellites for optical Earth observation. Among many other topics, this requires to rethink the way sattelites are being produced in order to ease this highly complex process. There is actually an unprecedented economical and societal demand for robots that can be used both as advanced and easily programmable tools for automatizing complex industrial operations in contexts where human expertise is a key factor to success and as assistive devices for alleviating the physical and cognitive stress induced by such industrial task. Unfortunately, the discrepancy between the expectations related to idealized versions of such systems and the actual abilities of existing so-called collaborative robots is large. Beyond the limitations of existing systems, especially from a safety point of view, there are very few methodological tools that can actually be used to quantify physical and cognitive stress. There is also a lack of formal approaches that can be used to quantify the contribution of collaborative robots to the realization of industrial tasks by expert operators. Of course, in the state-of-the-art, existing works in that domain do consider some aspects of the current state of the operator in order to propose an appropriate robot behaviour. One of their conceptual limitations is to consider an a priori defined human-robot collaboration scenario where the expertise of the human operator is of importance but limited to a single operation. The consideration of larger varieties of tasks is rarely considered and, when it is, only a strict separation of the tasks to be achieved by each member of the human-robot dyad is considered. In this project, we propose to develop a coupled model of human-robot physical abilities that does not make any a priori with respect to the type of assistance. This requires to develop a parameterisable generic model of the potential physical link and implied constraints between the human operator and the robot. This model should allow to describe the task to be achieved by the human alone or using a collaborative robot through different interaction modalities. Online simulation of these scenarios coupled with ergonomic and performance indicators should both allow for the discrete choice of the right assistance mode given the task currently being achieved as well as for the continuous modulation of the robot behaviour.

[Read More]